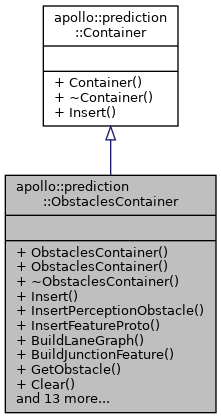
#include <obstacles_container.h>
◆ ObstaclesContainer() [1/2]
| apollo::prediction::ObstaclesContainer::ObstaclesContainer |
( |
| ) |
|
◆ ObstaclesContainer() [2/2]
| apollo::prediction::ObstaclesContainer::ObstaclesContainer |
( |
const SubmoduleOutput & |
submodule_output | ) |
|
|
explicit |
Constructor from container output.
◆ ~ObstaclesContainer()
| virtual apollo::prediction::ObstaclesContainer::~ObstaclesContainer |
( |
| ) |
|
|
virtualdefault |
◆ BuildJunctionFeature()
| void apollo::prediction::ObstaclesContainer::BuildJunctionFeature |
( |
| ) |
|
Build junction feature for obstacles.
◆ BuildLaneGraph()
| void apollo::prediction::ObstaclesContainer::BuildLaneGraph |
( |
| ) |
|
Build lane graph for obstacles.
◆ CleanUp()
| void apollo::prediction::ObstaclesContainer::CleanUp |
( |
| ) |
|
◆ Clear()
| void apollo::prediction::ObstaclesContainer::Clear |
( |
| ) |
|
Clear obstacle container.
◆ curr_frame_considered_obstacle_ids()
| const std::vector<int>& apollo::prediction::ObstaclesContainer::curr_frame_considered_obstacle_ids |
( |
| ) |
|
Get non-ignore obstacle IDs in the current frame.
- Returns
- Non-ignore obstacle IDs in the current frame
◆ curr_frame_movable_obstacle_ids()
| const std::vector<int>& apollo::prediction::ObstaclesContainer::curr_frame_movable_obstacle_ids |
( |
| ) |
|
Get movable obstacle IDs in the current frame.
- Returns
- Movable obstacle IDs in the current frame
◆ curr_frame_obstacle_ids()
| std::vector<int> apollo::prediction::ObstaclesContainer::curr_frame_obstacle_ids |
( |
| ) |
|
Get current frame obstacle IDs in the current frame.
- Returns
- Current frame obstacle IDs in the current frame
◆ curr_frame_unmovable_obstacle_ids()
| const std::vector<int>& apollo::prediction::ObstaclesContainer::curr_frame_unmovable_obstacle_ids |
( |
| ) |
|
Get unmovable obstacle IDs in the current frame.
- Returns
- unmovable obstacle IDs in the current frame
◆ curr_scenario()
| const Scenario& apollo::prediction::ObstaclesContainer::curr_scenario |
( |
| ) |
const |
◆ GetClustersPtr()
| ObstacleClusters* apollo::prediction::ObstaclesContainer::GetClustersPtr |
( |
| ) |
const |
Get the raw pointer of clusters_.
◆ GetJunctionAnalyzer()
| JunctionAnalyzer* apollo::prediction::ObstaclesContainer::GetJunctionAnalyzer |
( |
| ) |
|
◆ GetObstacle()
| Obstacle* apollo::prediction::ObstaclesContainer::GetObstacle |
( |
const int |
id | ) |
|
Get obstacle pointer.
- Parameters
-
- Returns
- Obstacle pointer
◆ GetPerceptionObstacle()
| const apollo::perception::PerceptionObstacle& apollo::prediction::ObstaclesContainer::GetPerceptionObstacle |
( |
const int |
id | ) |
|
◆ GetSubmoduleOutput()
◆ Insert()
| void apollo::prediction::ObstaclesContainer::Insert |
( |
const ::google::protobuf::Message & |
message | ) |
|
|
overridevirtual |
◆ InsertFeatureProto()
| void apollo::prediction::ObstaclesContainer::InsertFeatureProto |
( |
const Feature & |
feature | ) |
|
Insert a feature proto message into the container.
- Parameters
-
◆ InsertPerceptionObstacle()
| void apollo::prediction::ObstaclesContainer::InsertPerceptionObstacle |
( |
const perception::PerceptionObstacle & |
perception_obstacle, |
|
|
const double |
timestamp |
|
) |
| |
Insert an perception obstacle.
- Parameters
-
| Perception | obstacle Timestamp |
◆ NumOfObstacles()
| size_t apollo::prediction::ObstaclesContainer::NumOfObstacles |
( |
| ) |
|
|
inline |
◆ SetConsideredObstacleIds()
| void apollo::prediction::ObstaclesContainer::SetConsideredObstacleIds |
( |
| ) |
|
◆ timestamp()
| double apollo::prediction::ObstaclesContainer::timestamp |
( |
| ) |
const |
The documentation for this class was generated from the following file:
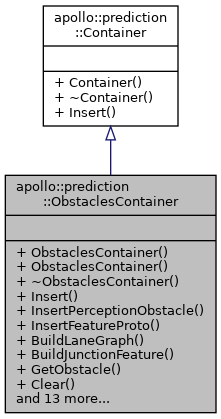
 Public Member Functions inherited from apollo::prediction::Container